I am a developer who thrives on building software tools and experimenting with new technologies. My focus is on creating interesting technical projects that solve real problems.
Whether it's an AI chatbot, a hardware GPS tracker, or a complex web app, I write code that pushes boundaries. Powered by caffeine, unhinged ideas, and an unhealthy UI obsession. Let's build something ridiculously cool.
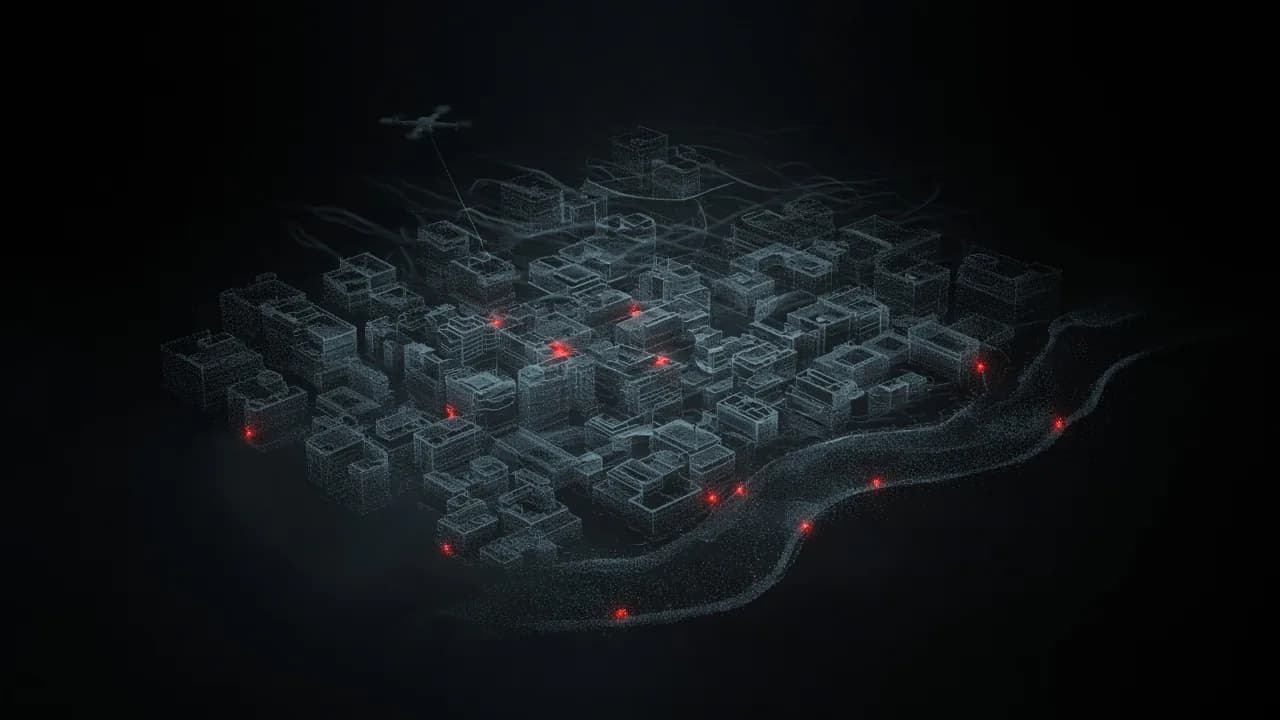
Live weather, Bow River levels, air quality, traffic incidents and OpenStreetMap buildings flow through one pipeline into an interactive Cesium map. LightGBM models forecast temperature, river level and PM2.5 across several horizons. An optional PX4 drone in Gazebo streams telemetry and can be flown over the neighbourhood from the browser.
Video from a pure event camera, held steady when the sensor stops.
A C++, CUDA and TensorRT pipeline that packs event camera data into voxel grids on the GPU and reconstructs video with FireNet. When a MEMS gyroscope says the sensor is still, it skips inference and holds the last good frame instead of letting the picture fade to gray. Research code for a paper from the Intelligent Navigation and Mapping Lab.
The public site and team portal for the ROAM robotics club.
The website for ROAM, a student robotics club building an autonomous rover for LiDAR mapping. It opens on a Mars scene where the rover drives in, and runs browser demos: an A* path planner, a 3D navigation simulator, an exploded sensor rig and a point cloud view. Behind sign-in, a team portal handles recruitment, the member roster and club email.
A scanning rig split across two Raspberry Pis and a laptop over ROS 2. One Pi runs OpenVINS visual-inertial odometry from a camera and IMU, the other maps with LiDAR and closes loops in RTAB-Map. The laptop watches the live map in Foxglove, and two extra cameras record footage for offline COLMAP reconstruction.